2026 · Robotics / ROS 2 / AI/ML
RobotOps
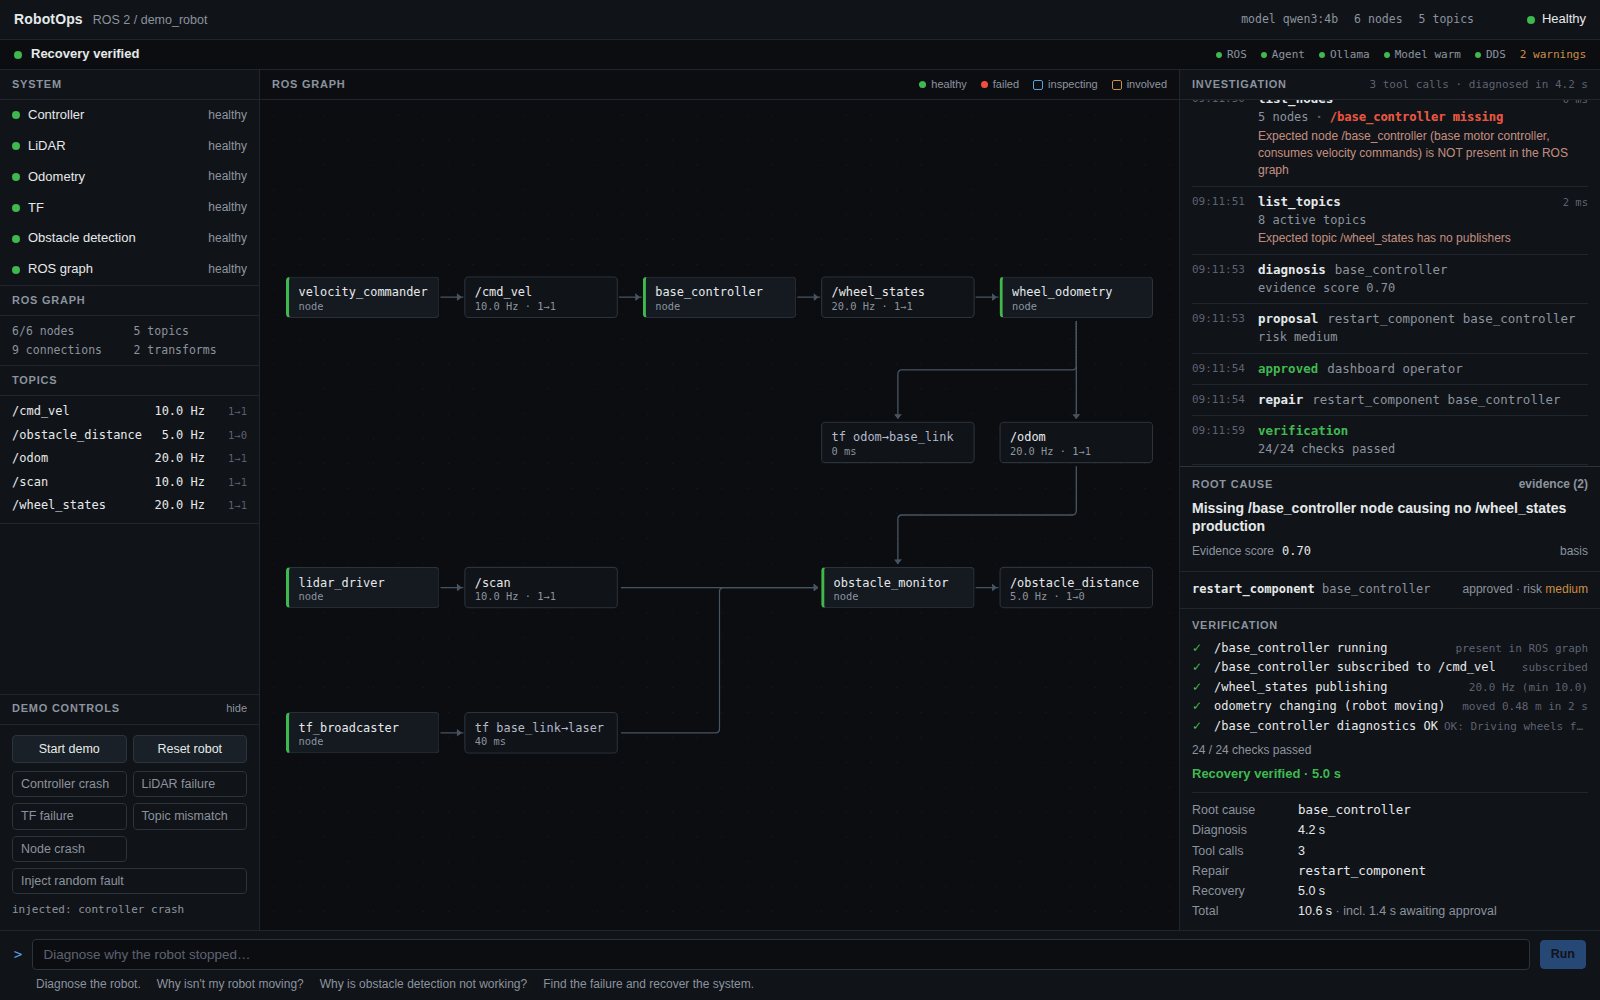
A local-first reliability engineer for a live ROS 2 graph. RobotOps gathers runtime evidence, validates a model's cited diagnosis, gates the only repair behind approval, and re-measures recovery.
Problem
ROS failures are distributed: an operator sees a symptom, then manually traces nodes, topics, TF, diagnostics and logs before trusting any recovery.
What I built
- A FastAPI and React investigation console over a live rclpy demo robot.
- An explicit agent state machine where a local model can select read-only observations and cite evidence, but cannot execute commands.
- A single-use approval gate, allowlisted restart primitive, audit log, and post-repair verification path.
Technical approach
The tool layer creates timestamped evidence IDs from ROS measurements. The diagnosis validator checks that cited evidence exists, comes from independent tool calls, and concerns the claimed component. Recovery is reported only after the verifier re-measures the system.
What I learned
The important boundary is not prompting: it is keeping observation, evidence, authorization, actuation and verification in deterministic code. The repository documents a bounded demo fault set; it does not claim general hardware reliability.
Let’s connect
I’m always open to discussing robotics, autonomous systems, or new projects. Just reach out!