2026 · Robotics / Robot Learning / Simulation / AI/ML
MiniRDT-SO101
A compact RDT-inspired policy pipeline that treats simulator validity, closed-loop evaluation, and failure analysis as first-class engineering work.
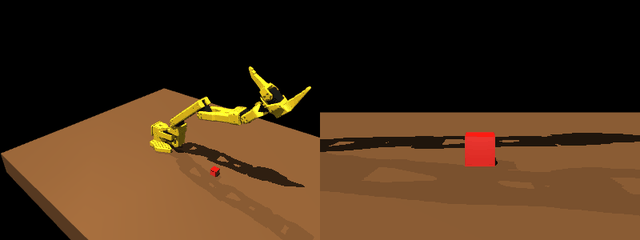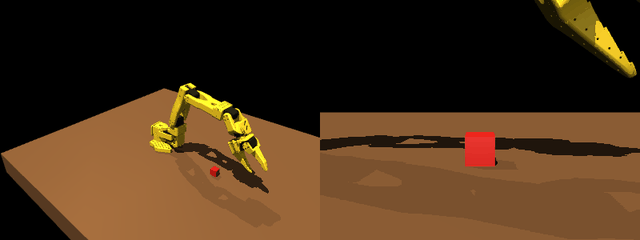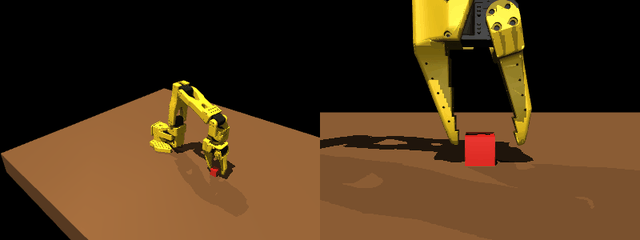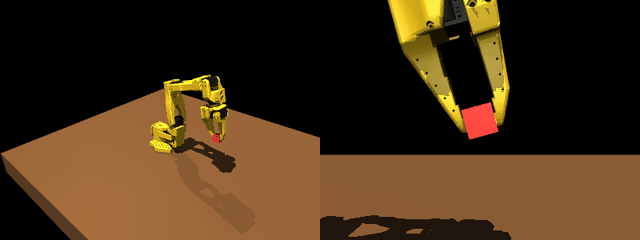
Problem
A manipulation benchmark can look successful while being physically invalid. An audit found the original scene allowed table penetration, invalidating its earlier grasp results.
What I built
- A physics-v2 MuJoCo task with table contact, calibrated contacts, a side-pinch expert, and explicit success checks.
- TinyRDT: a 4-layer Transformer conditioned on vision, proprioception and diffusion time, predicting 16 joint-target actions.
- Data collection, closed-loop diagnostics, generalization probes and regression tests alongside the policy code.
Technical approach
The policy runs receding-horizon control: observe, sample an action chunk, execute a prefix, and observe again. The evaluation distinguishes memorized scenes from held-out positions and logs contact validity rather than relying on a single visual success signal.
What I learned
The project keeps invalid physics-v1 results in the history rather than presenting them as wins. Offline loss was not enough to predict closed-loop skill, and spatial coverage mattered more than raw demonstration count in the documented experiments.
Let’s connect
I’m always open to discussing robotics, autonomous systems, or new projects. Just reach out!