2026 · Robot Learning / Simulation / AI/ML
MicroDuck Genesis
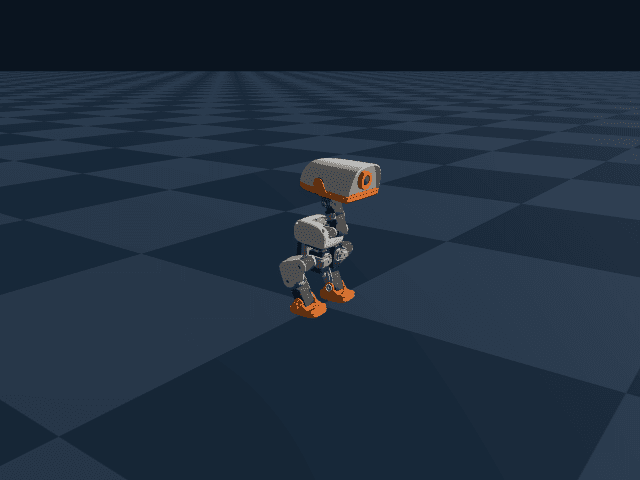
An in-progress simulator and RL validation effort focused on preserving observation, action, reward and actuator contracts before attempting locomotion training.
Problem
Moving a robot-learning task between simulators can silently change contacts, observations or actuators. Training before measuring those differences would make results hard to interpret.
What I built
- A Genesis environment with actor and privileged-critic observation streams kept separate.
- PPO, reward, termination, randomization and actuator modules, plus replay and trajectory comparison scripts.
- Contract tests and written parity scorecards for observation, reward, trajectory and BAM actuator behavior.
Technical approach
The work compares a reference MuJoCo trace with Genesis replay, then uses staged GPU smoke tests and short PPO runs to validate numerical behavior. The repository records throughput separately from locomotion quality.
What I learned
The current repository explicitly says it is not ready for locomotion training: the short PPO experiment was stable but did not produce validated forward locomotion. That limitation is part of the project story, not something to hide.
Let’s connect
I’m always open to discussing robotics, autonomous systems, or new projects. Just reach out!